TU Delft Researchers Create Soft Robotics that Respond to Color-Based Sensors
 As 3D printing and robotics continue to collide and complement each other, new machines are being created. In soft robotics, we’re seeing the emergence of a class of machines that can deform or morph in response to their environments.
Rob Scharff, a PhD candidate at TU Delft, discusses more how these robots are able to change color via sensors and shape, moving further toward closed-loop control of soft robots, with further research published in ‘Color-based Proprioception of Soft Actuators Interacting with Objects.’ The researchers explain their goal to create soft robots that can interact with items that were previously unknown to them, using color-based sensors.
“Our results demonstrate that deformations of the actuator during interaction, including the sigmoid-like shapes, can be accurately reconstructed. The accurate shape sensing represents a significant step towards closed-loop control of soft robots in unstructured environments,” state the researchers.
Scharff explains soft robotics as the softer, more adaptive robot for today—as well as pointing out that their gripping devices have become much more attuned to handling items like fruits or vegetables, for example, making them useful for industries such as grocery stores or their warehouses—and in exercises where the items they are gripping could be unpredictable in size or fragility.
Why can’t we use traditional sensors in soft robots?
“Traditional robots typically have joints that revolve around a single axis,” says Scharff. “Therefore, a single encoder in each joint is enough to reconstruct the robot’s shape. In contrast, soft robots can bend, stretch and twist at the same time, making existing sensors unsuitable. Therefore, we need sensors that can capture a large variety of deformations. Besides that, the sensors need to be flexible so as not to impede the actuators movement.”
How do your sensors work?
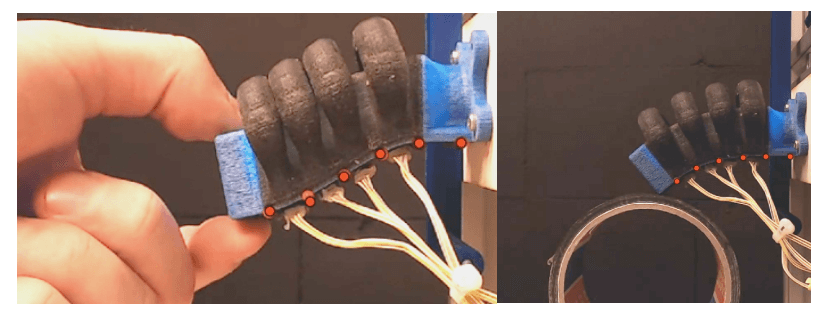
“The bending actuators shown in this research consist of an air chamber with an inextensible layer at the bottom, and an extensible bellow-shape at the top. Inflating the air chamber will cause the bellows at the top to expand, while the bottom remains at the same length, creating a bending motion. We 3D print a color pattern inside these top bellows and observe these color patterns with color sensors at the inextensible bottom of the actuator. When the actuator is inflated, colors that were previously occluded from the sensors start to appear. We use this change in color and the changes in light intensity to predict the shape of the actuator.”

How do you derive the position from this color?
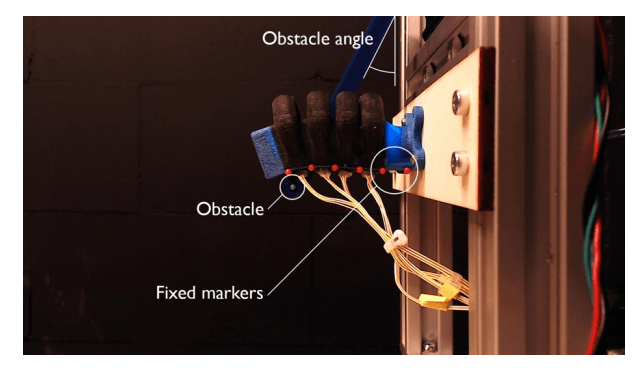
“We calibrate the sensors using a feedforward neural network. To train the network, we collected 1000 samples of sensor values with corresponding actuator shapes. The actuator shapes were represented by 6 markers on the inextensible layer that were tracked by a camera. The inputs of the network are the readings from 4 color sensors with 4 channels (red, green, blue, white) each.”
What is the accuracy of your new method?
“Our method is able to predict the position of each of the markers with an error that is typically between 0.025 and 0.075mm. Our method also performs well on load cases that were not present in the training data. Unlike existing sensors in soft robotics, we can measure the exact shape of how the gripper is bent around an object. Therefore, the work is a big step towards being able to accurately move and grasp objects with soft robots.”
How are the actuators fabricated?
“The actuators are fabricated as a single piece using PolyJet multi-material Additive Manufacturing. The bellows are fabricated using the flexible Agilus Black material, whereas the colored structure is composed of alternating segments of VeroCyan and VeroMagenta. The custom sensor PCB’s are embedded on small 3-D printed plugs that are plugged into the bottom of the actuator to create an airtight fit. Color sensors are very cheap and accessible which makes it easy to implement the technique in other soft robots as well.”
3D printing in multiple materials, as well as multiple colors, is becoming more common as technology and hardware catch up with concepts and user demands, along with the accompaniment of sensors, electronics, wearables, and much more. What do you think of this news? Let us know your thoughts; join the discussion of this and other 3D printing topics at 3DPrintBoard.com.
[Source / Images: TU Delft]Subscribe to Our Email Newsletter
Stay up-to-date on all the latest news from the 3D printing industry and receive information and offers from third party vendors.
Print Services
Upload your 3D Models and get them printed quickly and efficiently.


You May Also Like
AM Demand Signals: the Tungsten Harbinger
Most everyone who’s concerned with the scarcity of industrial materials is focused on rare earths, and rightfully so. But aside from the direct impact resulting from tighter supplies of rare...
WASP Mixes Earth and Plastic to Make Recyclable 3D Printed Composites
WASP has an eco-friendly ethos. Indeed, the firm wants to build houses and communities using local, environmentally friendly, and sustainable materials. WASP works with ceramics, biocement, and earth. The company...
3DPOD 318: 3D Printing at ORNL, Part II – Thomas Feldhausen
Thomas Feldhausen works at Oak Ridge National Laboratory (ORNL) on hybrid manufacturing, DED, digital twins, and new manufacturing solutions. For years, he’s tried to marry traditional subtractive manufacturing with additive...
The First Million’s the Hardest: Carbon’s Achievement with 3D Printed Bike Saddles
Last month I wrote an ode to 3D printed football helmet liners, as well as a brief overview of some of the biggest additive manufacturing (AM) success stories for the...